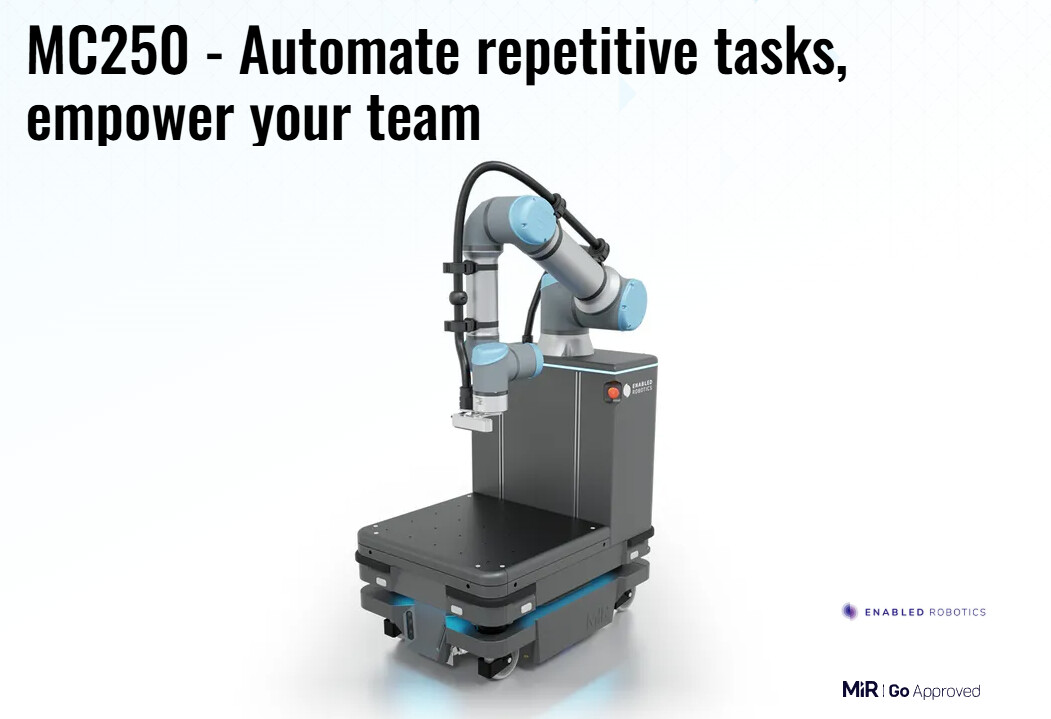
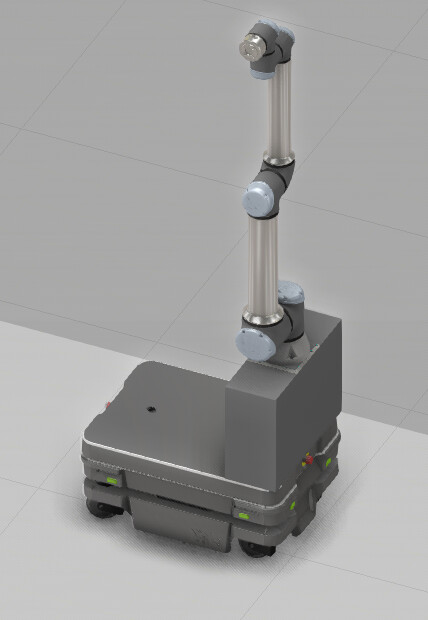
My Boss asked me to make a line with a MIR and a Cobot attached to it for pick and place delivery. i cant find MC250 in the eCat as well as any reference io this. i was thinking of modifying the model of the MiR250 and just placing a block on top of it for the pedestal. then pasting a robot controller on top of the block so that i can plug n’ play the UR in the MIR250. But i don’t think it’s possible or i just don’t know how to properly execute it.
Hi Lemmy,
It is actually enough to attach the robot to the mobile robot and then use mobile robot transport controller to move the mobile robot around. The attached robot should be used automatically. To attach check the home tab:
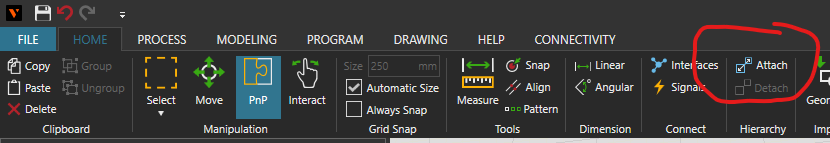
You can also check the process modelling resources manual, page 11
br,
lefa