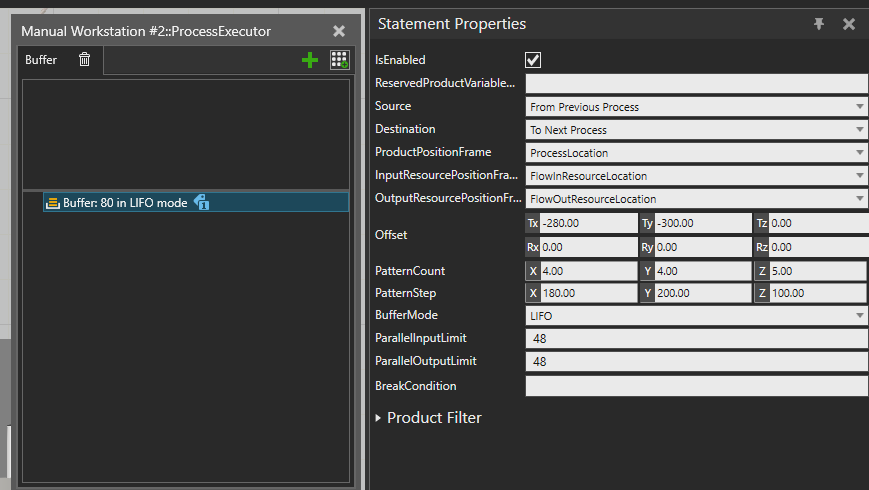
An AMR with an attached robot arm is placing products into a buffer. The issue: the AMR is moving and turning itself before each pick. It should just stay in place and let the robot arm empty its capacity.
What to change?
An AMR with an attached robot arm is placing products into a buffer. The issue: the AMR is moving and turning itself before each pick. It should just stay in place and let the robot arm empty its capacity.
What to change?
Add these two properties in the AMR component, if the AMR doesn’t have those already:
Transport::EnablePickPlaceTolerance (Boolean)
Transport::MoveTolerance (Real)
The common resource script in all AMR:s references to those properties in doing that part of the motion.
Toggle the boolean property on and adjust the MoveTolerance so that it’s greater than the distance the mobile robot would need to travel. This eliminates some of the unnecessary motion, and if you adjust the resource locations carefully (source and destination exactly in same X,Y,Rz), even eliminate all of the unnecessary motion.
Thanks @KustiH, that does improve the movements.
Another question - in my case the AMR is driving up and down a narrow corridor between shelves. At the moment in rotates itself for every movement. Realistically, it would drive in one way and then move back the other way. Is there a way to achieve this sort of movement?
@KustiH … actually it seems with these parameters it became even worse, because now the robot runs immediately into a position out of reach error.
At the same time I have a similar issue with the human walking into tables to pick the products.
Flow in and out locations are properly defined - I don’t get it why the resources don’t just stay in those locations to collect or place products.
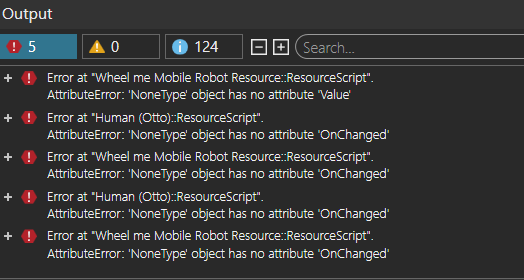
@KustiH AMR resource suddenly stopped working all together after playing with the parameters:
Wasn’t 5.1 supposed to introduce some better solutions for resource management, path planning, avoidance and so on? Is there anything I can utilise in this case that would resolve these issues?
Problem is that if the AMR/human doesn’t move realistically, any person looking at the simulation will notice it immediately and call it out.
Was able to resolve a few things meanwhile:
LimitSpeed and LimitCapacity props any more  Recreated all of them.
And I’m still stuck with the following issues:
Any ideas?
Hi,
Sounds like you had extremely bad luck with the pathway areas.
Are you using resource components from the normal categories (“Mobile Robots”, “Resources”), or from the new resource components category “Navigation (Beta)”? My advise with the EnablePickPlaceOffset and MoveTolerance was information based on the normal (old) resource logic, so it might be that the new navigation logic does not support parts of that yet.
Could you share the layout to support?
Sounds like you had extremely bad luck with the pathway areas.
This is not the first time either. I reported the same issue to support a few months ago, but unfortunately they said ‘cannot reproduce’ and the case was closed.
Very strange how components can suddenly ‘lose’ a few of their properties. Everything there is from the standard catalog.
Could you share the layout to support?
I’d like to, but am getting no response from support so far on this case (id 82046). Maybe you can help push it a long a bit if possible.
Thanks!